Engineering approaches to robotic rehabilitation
A research perspective on adaptive robotic assistance, sensing and evaluation for rehabilitation technologies.
Abstract
Robotic rehabilitation combines mechanical design, sensing and control to support structured movement practice. This research perspective examines how assistance can be adapted to the task and to information available from the user and device. It considers the relationship between safe interaction, interpretable measurements and the practical requirements of an engineering evaluation.
Research question
How can a rehabilitation device provide useful assistance while allowing movement quality and participation to be assessed? A system needs to distinguish the force supplied by its actuator from the movement contributed by the person using it. That distinction affects both controller design and the interpretation of recorded performance.
Engineering approach
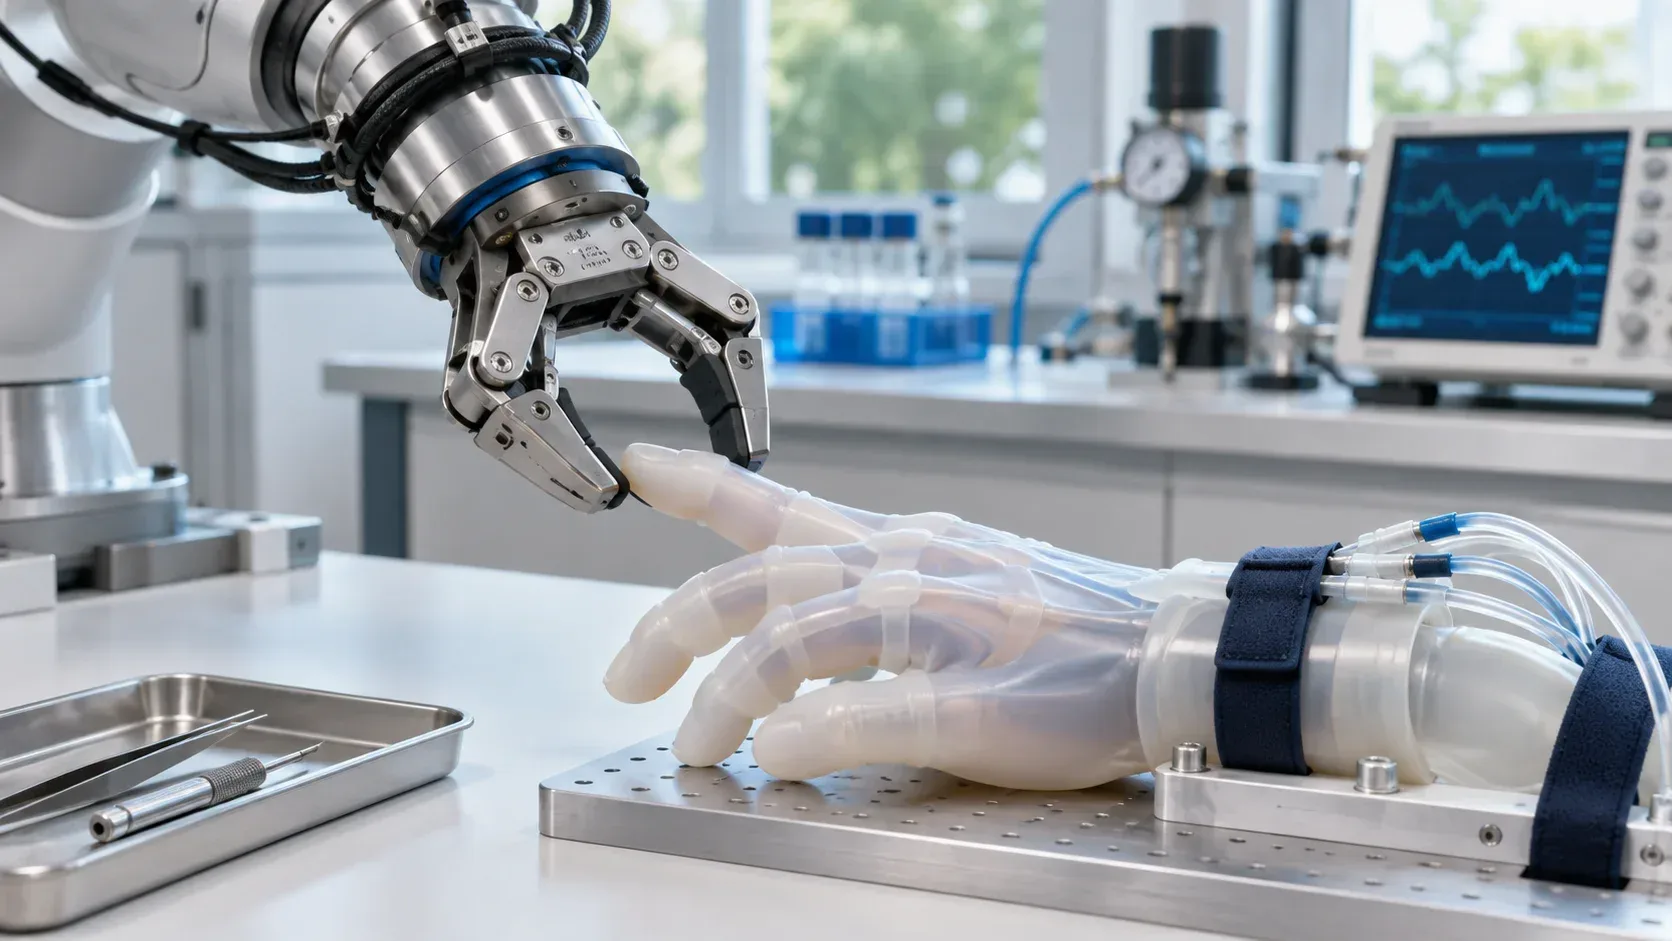
A proposed workflow combines a compliant mechanism with position and interaction-force measurements. The controller can adjust assistance within defined operating limits, while an analysis pipeline records movement consistency, task completion and the behaviour of the device. Bench testing can first examine repeatability and responses to controlled disturbances before any study involving participants is considered.
Discussion and limitations
Device measurements describe only part of rehabilitation. Results must be interpreted alongside the task, study design and characteristics of the participants. Engineering performance does not establish clinical benefit on its own. Further work can examine usability, longer-term reliability and how the system might fit into a supervised rehabilitation workflow.
Related research
Explore the Robotics and Devices research area and its connected rehabilitation project.